Description
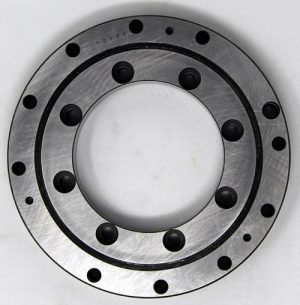
Cross roller bearing J4 for Mitsubishi RV-4A and RV-3AL robots
The cross roller bearing J4 RV-4A is a precision rolling bearing for the fourth axis of the Mitsubishi industrial robots RV-4A and RV-3AL. This RV-3AL cross roller bearing forms the link between the main axes and the wrist axes of the robot. The J4 axis is the first wrist axis and enables the rotation of the entire wrist module – the cross roller bearing has to absorb both the dynamic forces of fast rotary movements and the static loads of the tool.
Technical features
- Type: cross roller bearing
- Axis position: J4 (first wrist axis)
- Compatible with: Mitsubishi RV-4A, RV-3AL
- Load type: radial, axial and tilting moment load
- Design: for dynamic rotary movements with tool load
- Suitable for various Mitsubishi robot models
Role of the J4 axis in the robot system
The J4 axis is the rotary axis of the robot wrist and is activated in almost every motion profile. On the RV-4A with a payload of 4 kg and the RV-3AL with its extended arm, considerable dynamic loads act on the J4 cross roller bearing due to the mass inertia of the tool and workpiece. A bearing replacement in this position requires disassembly of the wrist module and subsequent recalibration of all wrist axes. Early detection of bearing wear – for example through vibration measurement – can prevent unplanned downtime.
Availability and notes
Mitsubishi has discontinued this series – now only available in limited quantities worldwide. We recommend forward-looking spare parts stockpiling. Sold without warranty.
Alongside spare parts, ROBTEC also offers retrofit and maintenance services for your Mitsubishi robots. Bearing replacement, calibration and commissioning – all from a single source.
Contact us via our contact form – we support you with the procurement and installation of your cross roller bearing J4.